XELA Robotics — Bringing 3D Touch to Physical AI
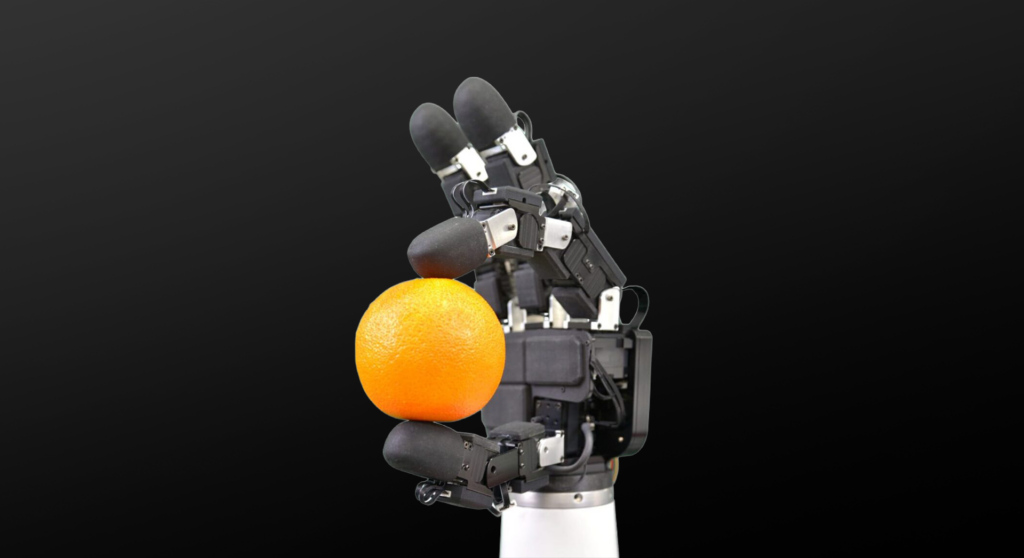
As robots move from structured automation into environments where they need to grasp, manipulate and interact with unpredictable objects, vision and proprioception alone leave a significant sensing gap: what is actually happening at the point of contact? XELA Robotics approaches this problem with uSkin, a thin, compliant tactile sensing platform designed to give robots distributed […]
Creating Soft Interfaces for Physical AI – Highlights from the WT Conference USA
We’ve spent the last few decades making machines increasingly intelligent. We optimized for computation, recognition, prediction, and reasoning – and for the most part, that intelligence lived safely behind a predictable screen. Physical AI changes everything. The moment intelligence leaves the screen, it has to deal with the physical world. And the physical world is […]